01 · Data input
ACORN
Capture · Record
It starts with real manipulation, captured as data.
01 · Data input
Capture · Record
It starts with real manipulation, captured as data.
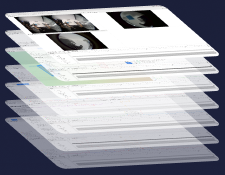
02 · Data processing and model training
Organise · Learn
Connects captured data to model training.
03 · Dexterous hand output
Execute · Verify
Carries learned motion back into the real world.
Human manipulation→ACORN UMI-L→Pose / hand / dexterous hand data→Time sync→SDK / dataset→OAK / robot control
CAPTURE THE REAL WORLD
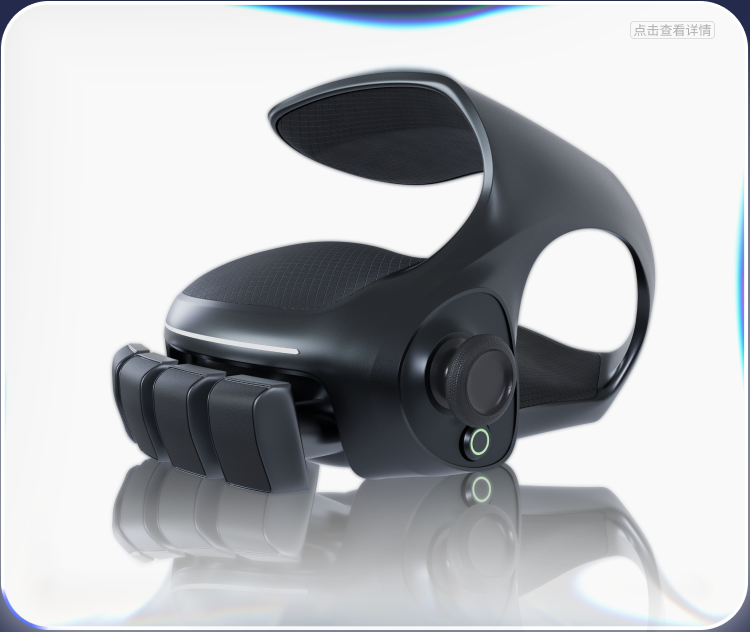
01·Real-world capture
First-person video, head and hand pose, and two-hand input are recorded together. A supported dexterous hand and wrist cameras add their state and close-range video.
The left and right UMI controllers drive the mounted hand directly, so capture happens in the field rather than at a fixed teleoperation station.
02·Direct force feedback
The handheld controllers drive the mounted hand directly, so contact and resistance are felt during the task and motion adjusted as it happens.
03·Lower data cost
For the same task and data quality, unit data cost is about 1/6 of capture by teleoperating a real robot.
Internal estimate; results vary with configuration and process.
04·Dexterous hand support
Supported hands connect over CAN FD, and the position, velocity, current and status the interface exposes are recorded alongside.
Squirrel Robotics was founded in August 2025 to connect human manipulation with robot learning.
We start from real-world interaction and focus on real-world data capture and dexterous hand control, so every action becomes data that can be recorded, understood and learned from.
From capture to training to execution, data runs through every stage of embodied intelligence.